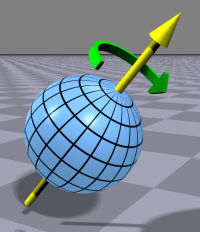
 In the last installment I introduced the idea of a transformation matrix — a square matrix that we view as a set of (vertically written) vectors describing a new basis for a transformed space. Points in the original space have the same relationship to the original basis as points in the transformed space have to the transformed basis.
When we left off, I had just introduced the idea of a rotation matrix. Two immediate questions were: How do we create a rotation matrix, and how do we use it. (By extension, how do we create and use any matrix?)
This is where our story resumes…






 Logos con carne

You must be logged in to post a comment.